Ihr Marktplatz für antiquarische und neue Bücher | Login | Neu registrieren Registrieren
Buchfreund als App

Goethes Mutter [Titel]

(1.233 Ergebnisse)
Titel
Goethes Mutter
Titel: Goethes Mutter
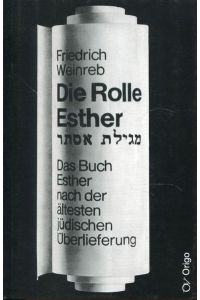
Weinreb, F Rolle Esther Das Buch Esther nach der ältesten jüdischen Überlieferung von Friedrich Weinreb Altes Testament Esther Buch Frau Juden Religion Eine eingehende Erläuterung des biblischen Textes aus dem alten jüdischen Wissen führt in bisher nie gesehene Zusammenhänge mit unserem Leben in der Krise der Moderne. Der Autor bezeichnet dieses Buch zusammen mit Schöpfung im Wort und Jonah als die drei wichtigsten literarischen Werke, die das Fundament für seine gesamten Ausführungen bilden. Im Buch bezieht sich Weinreb immer wieder auf den Bauplan. Dieser ist die gekürzte Fassung von Schöpfung im Wort, welches erst viele Jahre später als vollständige Übersetzung seines niederländischen Hauptwerkes De Schepping erschienen ist. Vorwort: Esther heißt auf hebräisch: «Ich, der Ich verborgen bin. » Nach der jüdischen Überlieferung ist das Sich-Verbergen Gottes in der Sichtbarkeit der Welt gemeint. Und von diesem Sich-Verbergen Gottes heißt es, es sei die Folge einer Abwendung des Menschen. Einen verborgenen Gott nennt man leicht einen schlafenden Gott, wenigstens einen sich um die Welt nicht direkt kümmernden Gott. Und so meint man schließlich, daß Gott gar nicht existiere. Man kann ja, ohne jede Rücksicht auf Gott, die Welt ausgezeichnet selber lenken und alles selber in die Hände nehmen. Die Resultate der Wissenschaft und der Technik scheinen diese Haltung und diese Maßnahmen zu rechtfertigen. Und doch hat diese Lebenshaltung einen vorher unbekannten Pessimismus, große Lustlosigkeit und eine düstere Untergangsstimmung hervorgebracht. Viel Egoismus, Härte und Immoralität. Dort, wo die Bibel nicht nur als ein Produkt der menschlichen Geschichte gilt und man in der Bibel noch die Grundstruktur des menschlichen Wesens und der Menschheit erblickt, ist man sich dieser Aspekte bewußt. Diese Probleme sollten in einem viel größeren Zusammenhang gesehen werden. Beim sorgfältigen Untersuchen und Vergleichen des hebräischen Textes wird eine Grundstruktur der biblischen Sprache erkennbar. Diese Grundstruktur offenbart die Bibel als ein Wunderwerk. Wie es die Wunder der Natur gibt, die das Äußere unserer Welt bestimmt, so gibt es auch die Wunder des Wortes. Sie durchdringen das Wesen der Menschheit und jedes einzelnen Menschen. In meinem Buche «Schöpfung im Wort» habe ich einiges dazu ausgeführt. Vor allem wollte ich davon sprechen, welchen gangbaren Weg, welche ernsthafte und zu verantwortende Methode es gibt, um sich im Worte zu den allgemein menschlichen Werten zurückzufinden, was für unsere Zeit von nicht abzuschätzender Bedeutung wäre. Zum Gegenstand einer ersten speziellen Veröffentlichung wählte ich, nach der genannten allgemeinen Einführung, aus dem umfangreichen Material der Überlieferung die Esther-Erzählung. Es hätte ebensogut ein anderer Teil des großen Ganzen der Bibel sein können. Alle Teile haben durch die besondere Wortwahl und Strukturierung der Bibel dieselbe aktuelle und allgemeingültige Bedeutung. Sagen wir einmal, daß die Wahl dieses Gegenstandes dem «Zufall» zu verdanken ist. Man wird sehen, daß die Esther-Erzählung auf das Phänomen «Zufall» ein typisches Licht wirft. Man kann dieses Buch ohne weiteres lesen, auch wenn man die Grundlagen der Erklärung nicht kennt. Möglicherweise wird man aber nach der Lektüre dieses Buches gerne einmal zu den einführenden Betrachtungen greifen, denn faszinierend ist manches auf jeden Fall. Es ist ratsam, die Esther-Erzählung, wie sie sich in der Bibel aufgezeichnet findet, zunächst einmal durchzulesen und sie hernach, während der Lektüre dieses Buches, zur Hand zu haben. Es ist zu empfehlen, eine Bibel beizuziehen, auch wenn man in ihr sonst nicht recht zu Hause ist. Man mache sich ja keine Sorgen, wenn man das Hebräische nicht versteht. Es wurde darauf geachtet, daß jedermann dies Buch ohne Mühe lesen kann. Für den Kenner des Hebräischen sind dort, wo es erforderlich ist, die hebräischen Wörter transkribiert wiedergegeben. Dabei sei beachtet, daß das ch wie ein hartes g ausgesprochen werden soll. Speziell Interessierte finden am Schlusse des Buches ein Quellenverzeichnis. Wie schon im Vorwort von «Der göttliche Bauplan» erwähnt, beruht meine Art der Annäherung an den Sinn auf alten, oft uralten Quellen. Man sollte sie wieder schätzenlernen. Es sind nicht bloß seltsame oder lehrreiche Geschichten, nützliche oder interessante Informationen über Sitten und Gebräuche. Man wird in ihnen auf das Warum der in Bildern verhüllten Einkleidung stoßen. Damit die Lektüre nicht unnötig durch Anmerkungen unterbrochen werde, bilden Quellenangaben, Hinweise und Notizen, unter jeweiligem Hinweis auf die Buchseite und das betreffende Thema, den Anhang des Buches. Wer tiefer in die Materie einzudringen wünscht, für den mögen sie wichtig sein. Die wichtigsten Quellen, aus denen geschöpft wurde, sind der «Midrasch Esther Rabbah», der «Traktat Megillah» aus dem «Talmud Bawli» (Babylonischer Talmud) der «Targum» und der «Targum Scheni» über Esther. Jüngere Quellen als die des späteren Mittelalters sind im allgemeinen nicht verwendet. Eine ausführlichere Bibliographie ist im «Der göttliche Bauplan» enthalten. Im Vorwort jenes Buches ist auch die Rechtfertigung für diese Veröffentlichung gegeben. Friedrich Weinreb Inhaltsverzeichnis: I. TEIL: DER SINN DER VERBANNUNG Der Untergang des Tempels 19 Geburt in die Verbannung 20 Lernen vor der Geburt 22 Die Ankündigung der Verbannung 22 Die Geburt und das Vergessen 24 Das verlorene Paradies 26 Das Muster der Schöpfung 27 Der Sinn des Vergessens 30 Das «Umsonst»-Handeln 32 Geschichte auf verschiedenen Ebenen 35 Der kritische Augenblick der Geburt 35 Die Geburt der letzten Neschamah 36 Die menschliche Entwicklung 37 Der Cham-Komplex 38 Der andere Aspekt der Geschichte 39 Die Bibel als Buch der Geschichte 41 Die Haltung von Schem-Jafeth 43 Das Erwachen aus dem Rausch 45 «Wir werden handeln und hören» 46 Der Prophet und sein Handeln 48 Verbannung auf dem Höhepunkt der Entwicklung 52 Die Verbannungen nach der Zerstörung des Tempels 54 Vier Verbannungen 55 Warum die Esther-Erzählung ein Teil der Bibel ist 56 Esther ist die Geschichte von der Verbannung 58 II. TEIL: DIE WELT DER NAMEN Die Begriffe Schem und Eber 63 Der Name Esther 65 Gott verbirgt sich 66 Die Ursache des Zufalls 68 Zufall und Mysterium 74 Die unerklärliche Halachah 73 Halachah und Neschamah 82 Das Ärgernis des Unauffälligen 84 Die Geschichte von den Sechsunddreißig Tsadikim 86 Versteckspiel 89 Die Suche nach dem «nistar» 90 Der Begriff «pur» 91 Der Ort der Handlung: «poras u-modai» 93 Die Erzählung auf der Rolle 95 Der König 99 Der Narr 103 Die Grenzen des Reiches 105 Die 127 Länder des Königs 108 «Schuschan», die Rose unter Dornen 110 Das Geheimnis der Rose 112 Die Rose in der Schöpfung 114 Schoschanah und Esther 119 Die Rose und das Veränderliche 120 Wodurch die Schöpfung sich bewegt 123 Achaschwerosch, der beunruhigte König 125 Die Regierung der Welt 126 Der Wein bei der Mahlzeit 127 Die Myrte 131 Esther ist grün 133 Esther - die Morgendämmerung 135 Die schönste und mächtigste Frau der Welt 138 Waschti und die Frauen der Iwrim 141Das Mysterium der Tat 143 Die Kraft der Entwicklung 145 Das Mitleid mit Amalek 147 Haman und Mordechai auf dem Weg in die Verbannung 151 Abel hätte Kajin erschlagen können 152 «Hast du nicht von dem Baum gegessen?» 153 Die Myrrhe im Salböl 156 Der Hirsch und die Hindin 160 Der Erlöser am Tor 162 Mordechai steht allein 162 Die Erkenntnis bringt die Lehre von den Letzten Dingen 165 III. TEIL: DIE GESCHICHTE DER ROLLE A. Der Weg der Entwicklung Die Hamsterer 169 Das Festmahl im dritten Jahr 173 Nur das halbe Reich 177 Entwicklung und Überfluß 177 Duldsamkeit und Wohlstand 178 Die herausgeforderte Königin 181 Das Naturgesetz versagt 184 Tsora-at» ? die schändliche Krankheit 185 Das Festmahl endet in Verwirrung 186 Waschtis Sturz 189 Waschti und Memuchan 191 Der König versinkt in Nachdenken 193 Die Jungfrauen und die Vierheit 194 Die verborgene Schönheit 197 Die Verbindung zwischen Mordechai und Esther 198 Esthers Schweigen 200 Der geschwätzige König und die schweigsame Frau 201 Die Zwei verliert ihren Platz an die Eins 203 Die Genesung geht der Krankheit voraus 206 Drei, Vier und Fünf 207 Mordechai ist Haman ein Dorn im Auge 208 Alle logische Beweisführung ist Zufall 209 Die Zwölf und die Dreizehn 213 Der Siegelring des Königs 214 Die Weisen der Welt geben sich geschlagen 217 Die undeutliche Botschaft 221 Es gibt keinen Käufer für die Verbannten 225 B. Die Krümmung Der dreizehnte Tag des Nissan 230 Die Vier Tage 232 In Sack und Asche 233 «Niddah» 235 Das «Geheimnis Daniel» 238 Von Esther wird das Unmögliche verlangt 240 Es gibt kein Entkommen 244 Die Fastenzeit und Ostern 245 Handeln wider die Natur 249 Esther lädt zum Mahle ein 253 Die Einladung an Haman 255 Das Geheimnis des ersten Mahles 258 Der von Haman bestimmte Baum 259Die Kinder des Lehrhauses 262 Das Wach-sein in der Nacht 267 C. Die Umkehr Haman ist sprachlos 273 Das kleine bißchen Mehl ist mehr 276 Auch Mordechai kann es nicht glauben 277 Haman muß die neue Welt verkünden 279 Esthers zweites Mahl 281 Die Dornen 282 In der neuen Welt ist alles umgekehrt 283 Träumend oder wachend? 284 Die Geschenke 288 Die wesentliche Entscheidung geht dem äußeren Kampf voraus 291 Der Triumph des Verborgenen 292 QUELLEN, ANMERKUNGEN UND HINWEISE 297 Weinreb, F: Rolle Esther Das Buch Esther nach der ältesten jüdischen Überlieferung von Friedrich WeinrebBeispielbild für diese ISBN

Weinreb, F Rolle Esther Das Buch Esther nach der ältesten jüdischen Überlieferung von Friedrich Wei…

von Friedrich Weinreb Verlag: Origo Bern

Auflage: 2. Auflage: 2. Softcover 316 S. 20,2 x 12,6 x 3 cm Zustand: gebraucht - sehr gut, Altes Testament Esther Buch Frau Juden Religion Eine eingehende Erläuterung des biblischen Textes aus dem alten jüdischen Wissen führt in bisher nie gesehene Zusammenhänge mit unserem Leben in der Krise der…

Gebraucht, sehr gut
Bestell-Nr.: BN26254
ISBN: 3282000022
Anbieter: BUCHSERVICE / ANTIQUARIAT Lars-Lutzer *** LITERA…, Wahlstedt, Deutschland

Verkäufer akzeptiert PayPal

48,90 EUR

zzgl. 6,99 EUR Verpackung & Versand
Applied Pattern Recognition: A Practical Introduction to Image and Speech Processing in C++ von Joachim Hornegger (Autor), Dietrich W. R. Paulus Algorithms and Implementation in C++ Design, structure and implementation of image and speech analysis systems - Digital filters, edge detection, image segmentation - Feature extraction from speech signals and classification - Fourier transform, image and speech compression - Introduction to C, C++ - Classes, inheritance and polymorphism Dietrich Paulus is a professor in computational visualistics at University Koblenz-Landau. Since over a decade he teaches image processing and programming languages. Joachim Hornegger is working for Siemens Medical Solutions, Inc. and the director of medical image processing. He is also a lecturer at the University of Mannheim teaching courses on medical image processing, discrete tomography, and 3D computer vision. From the contents: Design, structure and implementation of image and speech analysis systems - Digital filters, edge detection, image segmentation - Feature extraction from speech signals and classification - Fourier transform, image and speech compression - Introduction to C, C++ - Classes, inheritance and polymorphism Bildverarbeitung C++ Programmiersprache Efficient Algorithms Informatik EDV Image Processing Inheritance Mustererkennung Pattern Analysis pattern recognition Program Design programming regognition software development Speech processing Spracherkennung statistical pattern recognition ISBN-10 3-528-35558-1 3528355581 ISBN-13 978-3-528-35558-6 9783528355586 978-3528355586 Ein ganz großer Vorteil dieses Buches ist, dass die Thematik nicht nur auf einer abstrakten Ebene beschrieben wird, sondern dass im Buch immer wieder die Umsetzung der Aussagen in C++ gezeigt wird. neben einer Einführung in C++ werden die Algorithmen und Techniken immer wieder auch als Programm vorgestellt. Dadurch wird der Schritt von der Theorie - das heißt, dem als mathematische Formel beschriebenen Algorithmus - hin zur Praxis (dem Computerprogramm) durchgängig.  Elektronik This book demonstrates the efficiency of the C++ programming language in the realm of pattern recognition and pattern analysis. For this 3rd edition, new features of the C++ language were integrated and their relevance for image and speech processing is discussed. The description of the STL library was extended and STL is now used in many places in the book. The chapters 23 and 24 can now be used to build complete systems and give hints for further extensions. The book is divided into 4 parts. After an introduction to programming and software engineering, the required basics of image and speech processing are given. Statistics and mathematics is explained as required. The second part treats C++ as an object-oriented language and introduces it thru examples. In the third part the examples of the first and second part are combined to form an image segmentation and a word recognition system. All relevant features of the C++ language are thus introduced with direct relation to the tasks in image and speech processing. Die Behandlung der C++-Konstukte ist wirklich anwendungsnah.  Prof. Dr. Michael Schenke, FH Merseburg // sehr umfassend - anschaulich, klar, gut nachvollziehbar.  Prof. Dr. -Ing. Hans Peter Kölzer, HAW Hamburg Dieses Buch werde ich meinen Studenten empfehlen, weil es einen sehr anschaulichen und motivierenden Einstieg in die Mustererkennung bietet.  Prof. Dr. Hans-Peter Weber, FH Darmstadt Concerning 3rd edition: This book is a beautifully arranged marriage of state-of-the-art pattern recognition theory and of programming theory and practice. The elegant and thorough treatment of modern aspects of speech and video processing and interpretation springs to life through a multitude of well-designed case studies and concrete examples.  Carlo Tomasi, Prof. of Computer Science, Duke University, USA This book is a must for learners of practical image processing. The examples are well explained and cover the needs of a graduate image processing or pattern recognition course.  Laszlo Csink, Prof. of Computer Science, Budapest Polytechnic John von Neumann Faculty of Informatics, Hungary I am not aware of a book comparable to this one which gives an excellent combination of an account of relevant topics in pattern recognition as well as of techniques for implementing the equations and algorithms in C++. Therefore, the book is invaluable both to students starting in the field and and to practitioners needing a special algorithm and its implementation.  H. Niemann, Prof. of Computer Science, Friedrich-Alexander Universität Erlangen-Nürnberg, Germany // this book has been the perfect source for my students and me. Not only that the reader is elegantly and in a straightforward manner guided to the central points of the theory, but in parallel the authors also make it transparent how to implement the algorithms resulting from the theory.  Volkmar Welker, Prof. of Discrete Mathematics, University of Marburg, Germany Bildverarbeitung C++ Programmiersprache Efficient Algorithms Informatik EDV Image Processing Inheritance Mustererkennung Pattern Analysis pattern recognition Program Design programming software development Speech processing Spracherkennung statistical pattern recognition Applied Pattern Recognition A Practical Introduction to Image and Speech Processing in C++

Applied Pattern Recognition: A Practical Introduction to Image and Speech Processing in C++ von Joa…

4,00 Ødurchschnittliche Bewertung · 1 Bewertungen bei Goodreads

von Joachim Hornegger Dietrich W. R. Paulus Verlag: Vieweg+Teubner Verlag

4. Auflage 4th edition 4. Auflage 4th edition Softcover 372 S. 23,9 x 16,3 x 2 cm Zustand: gebraucht - sehr gut, Design, structure and implementation of image and speech analysis systems - Digital filters, edge detection, image segmentation - Feature extraction from speech signals and classificat…

Bestell-Nr.: BN25408
ISBN: 3528355581
Anbieter: BUCHSERVICE / ANTIQUARIAT Lars-Lutzer *** LITERA…, Wahlstedt, Deutschland

Verkäufer akzeptiert PayPal

199,90 EUR

zzgl. 6,99 EUR Verpackung & Versand
Springer Handbook of Robotics Incl DVD [Englisch] [Gebundene Ausgabe] Methods of Robotics Biologically-Inspired Robots Industrial Robotics Roboter Life-Like Robotics Manipulation and Interfaces of Robots Mobile and Distributed Robotics Roboethics Roboter Robotics Foundations Robot Structures Sensing and Perception of Robots Elektrotechnik Energietechnik ISBN-10 3-540-23957-X 354023957X ISBN-13 978-3-540-23957-4 9783540239574 Bruno Siciliano (Herausgeber), Oussama Khatib (Herausgeber) Robotik Robotertechnik Basic Principles and Methods of Robotics Biologically-Inspired Robots Industrial Robotics Life-Like Robotics Manipulation and Interfaces of Robots Mobile and Distributed Robotics Roboethics Roboter Robotics Foundations Robot Structures Sensing and Perception of Robots Elektrotechnik Energietechnik A new, authoritative and utterly comprehensive reference work on robotics that incorporates new developments, surpassing the narrow scope of other robotics handbooks that focus on industrial applications. Edited by internationally renowned experts. With the science of robotics undergoing a major transformation just now, Springer’s new, authoritative handbook on the subject couldn’t have come at a better time. Having broken free from its origins in industry, robotics has been rapidly expanding into the challenging terrain of unstructured environments. Unlike other handbooks that focus on industrial applications, the Springer Handbook of Robotics incorporates these new developments. Just like all Springer Handbooks, it is utterly comprehensive, edited by internationally renowned experts, and replete with contributions from leading researchers from around the world. The handbook is an ideal resource for robotics experts but also for people new to this expanding field. With the science of robotics undergoing a major transformation just now, Springer’s new, authoritative handbook on the subject couldn’t have come at a better time. Having broken free from its origins in industry, robotics has been rapidly expanding into the challenging terrain of unstructured environments. Unlike other handbooks that focus on industrial applications, the Springer Handbook of Robotics incorporates these new developments. Just like all Springer Handbooks, it is utterly comprehensive, edited by internationally renowned experts, and replete with contributions from leading researchers from around the world. The handbook is an ideal resource for robotics experts but also for people new to this expanding field. Bruno Siciliano is Professor of Control and Robotics at the University of Naples Federico II in Italy, President of the IEEE Robotics and Automation Society, and a Fellow of both IEEE and ASME. Oussama Khatib is Professor of Computer Science at Stanford University in the USA, President of the International Foundation of Robotics Research, an IEEE Fellow, and a recipient of the Japan Robot Association Award in Research and Development. Introduction (Bruno Siciliano, Oussama Khatib) Part A: Robotics Foundations (David Orin) Part A presents the fundamental principles and methods that are used to model, design, and control a robotic system. All of the foundational topics are included in this part: kinematics, dynamics, mechanical design and actuation, sensing and estimation, motion planning, motion control, force control, robotic systems architectures and programming, and AI reasoning methods for task planning and learning. A chapter is devoted to each of these topics. The topics are expanded and applied to specific robotic structures and systems in subsequent parts. Chap. 1. Kinematics (Ken Waldron, James Schmiedeler) Chap. 2. Dynamics (Roy Featherstone, David Orin) Chap. 3. Mechanisms and Actuation (Victor Scheinman, Michael McCarthy) Chap. 4. Sensing and Estimation (Henrik Christensen, Gregory Hager) Chap. 5. Motion Planning (Lydia Kavraki, Steve LaValle) Chap. 6. Motion Control (Wankyun Chung, Li-Chen Fu, Su-Hau Hsu) Chap. 7. Force Control (Luigi Villani, Joris De Schutter) Chap. 8. Robotic Systems Architectures and Programming (David Kortenkamp, Reid Simmons) Chap. 9. AI Reasoning Methods for Robotics (Joachim Hertzberg, Raja Chatila) Part B: Robot Structures (Frank Park) Part B is concerned with the design, modeling, motion planning, and control of the actual physical realizations of a robot. Some of the more obvious mechanical structures that come to mind are arms, legs, and hands; to this list can be added wheeled vehicles and platforms, and robot structures at the micro and nano scales. With separate chapters devoted to performance criteria and model identification, the chapters in this part successively examine serial redundant mechanisms, parallel mechanisms, flexible robots, robot hands, robot legs, wheeled robots, and micro- and nanoscale robots. Chap. 10. Performance Evaluation and Design Criteria (Jorge Angeles, Frank Park) Chap. 11. Redundant Manipulators (Stefano Chiaverini, Giuseppe Oriolo, Ian Walker) Chap. 12. Parallel Mechanisms and Robots (Jean-Pierre Merlet, Clément Gosselin) Chap. 13. Robots with Flexible Elements (Alessandro De Luca, Wayne Book) Chap. 14. Model Identification (John Hollerbach, Wisama Khalil, Maxime Gautier, ) Chap. 15. Robot Hands (Claudio Melchiorri, Makoto Kaneko) Chap. 16. Legged Robots (Shuuji Kajita, Bernard Espiau) Chap. 17. Wheeled Robots (Guy Campion, Woojin Chung) Chap. 18. Micro/Nano Robots (Brad Nelson, Lixin Dong, Fumihito Arai) Part C: Sensing and Perception (Henrik Christensen) Part C covers different sensory modalities and integration of sensor data across space and time to generate models of robots and the external environment. The main sensor types such as tactile, odometry, GPS, ranging and visual perception are presented. Both basic sensor models, sensor data processing and associated representations are covered. Finally, a chapter on sensor fusion itroduces the mathematical tools needed for integration of sensor information across space and time. Chap. 19. Force and Tactile Sensors (Mark Cutkosky, Robert Howe, William Provancher) Chap. 20. Inertial Sensors, GPS and Odometry (Gregory Dudek, Michael Jenkin) Chap. 21. Sonar Sensing (Lindsay Kleeman, Roman Kuc) Chap. 22. Range Sensors (Robert Fisher, Kurt Konolige) Chap. 23. 3D Vision and Recognition (Kostas Daniliidis, Jan-Olof Eklundh) Chap. 24. Visual Servoing and Visual Tracking (François Chaumette, Seth Hutchinson) Chap. 25. Sensor Fusion (Hugh Durrant-Whyte, Tom Henderson) Part D: Manipulation and Interfaces (Makoto Kaneko) Part D is separated into two subparts. The first half is concerned with manipulation where frameworks of modeling, motion planning, and control of grasp and manipulation of an object are addressed, and the second half is concerned with interfaces where physical human-robot interactions are handled. Chap. 26. Motion for Manipulation Tasks (Oliver Brock, James Kuffner, Jing Xiao) Chap. 27. Modelling and Manipulation (Imin Kao, Kevin Lynch, Joel Burdick) Chap. 28. Grasping (Jeff Trinkle, Domenico Prattichizzo) Chap. 29. Cooperative Manipulators (Fabrizio Caccavale, Masaru Uchiyama) Chap. 30. Haptics (Blake Hannaford, Allison Okamura) Chap. 31. Telerobotics (Günter Niemeyer, Carsten Preusche, Gerd Hirzinger) Chap. 32. Networked Teleoperation (Dezhen Song, Kenneth Goldberg, Nak Young Chong) Chap. 33. Exoskeletons for Human Performance Augmentation (Hami Kazerooni) Part E: Mobile and Distributed Robotics (Raja Chatila) Part E Mobile and Distributed Robotics, covers a wide span. The topics address motion planning and control of wheeled robots with kinematic constraints, perception and world modeling, simultaneous localization and mapping, and the integration of those capacities in a control architecture, as a mobile robot is actually the paradigm of a complex integrated system. In addition, multirobot interaction and systems are developed, including modular and reconfigurable robots as well as networked robotics. Chap. 34. Motion Control of Wheeled Mobile Robots (Pascal Morin, Claude Samson) Chap. 35. Motion Planning and Obstacle Avoidance (Javier Minguez, Florent Lamiraux, Jean-Paul Laumond) Chap. 36. World Modeling (Wolfram Burgard, Martial Hebert) Chap. 37. Simultaneous Localization and Mapping (Sebastian Thrun, John Leonard) Chap. 38. Behavior-Based Systems (Maja Mataric, François Michaud) Chap. 39. Distributed and Cellular Robots (Zack Butler, Alfred Rizzi) Chap. 40. Multiple Mobile Robot Systems (Lynne Parker) Chap. 41. Networked Robots (Vijay Kumar, Daniela Rus, Gaurav Sukhatme) Part F: Field and Service Robotics (Alexander Zelinsky) Part F covers topics related to creating field and service application based robots that operate in all types of environments. This includes applications ranging from industrial-robots, through a diverse array of air, land, sea and space applications to educational robotics. This part of the handbook draws on Parts A-E and describes how robots can be put to work. The chapters describe fit for purpose robots and include hardware design, control, perception, and user interfaces. The economic and social drivers for the particular applications are also discussed. Chap. 42. Industrial Robotics (Martin Hägele, Klas Nilsson, Norberto Pires) Chap. 43. Underwater Robotics (Gianluca Antonelli, Thor Inge Fossen, Dana Yoerger) Chap. 44. Aerial Robotics (Eric Feron, Eric Johnson) Chap. 45. Space Robots and Systems (Kazuya Yoshida, Brian Wilcox) Chap. 46. Robotics in Agriculture and Forestry (John Billingsley, Arto Visala, Mark Dunn) Chap. 47. Robotics in Construction (Kamel Saidi, Jonathan O’Brien, Alan Lytle) Chap. 48. Robotics in Hazardous Applications (James Trevelyan, Sungchul Kang, William Hamel) Chap. 49. Mining Robotics (Peter Corke, Jonathan Roberts, Jock Cunningham, David Hainsworth) Chap. 50. Search and Rescue Robotics (Robin Murphy, Satoshi Tadokoro, Daniele Nardi, Adam Jacoff, Paolo Fiorini, Howie Choset, Aydan Erkmen) Chap. 51. Intelligent Vehicles (Alberto Broggi, Alexander Zelinsky, Michel Parent, Charles Thorpe) Chap. 52. Medical Robots and Systems (Russell Taylor, Arianna Menciassi, Gabor Fichtinger, Paolo Dario) Chap. 53. Rehabilitation and Health Care Robotics (Machiel van der Loos, David J. Reinkensmeyer) Chap. 54. Domestic Robots (Erwin Prassler, Kazuhiro Kosuge) Chap. 55. Robots for Education (David Miller, Illah Nourbakhsh, Roland Siegwart) Part G: Human-Centered and Life-Like Robotics (Daniela Rus) Part G covers topics related to creating robots that operate in human-centered environments. This includes the design of robots with humanoid and other biologically inspired morphologies, sensors, actuators, and control architectures. User interfaces such as programming by demonstration and programming for safety are also included in this part. The part concludes with the socio-ethical implications of robots. Chap. 56. Humanoids (Charles Kemp, Paul Fitzpatrick, Hirohisa Hirukawa, Kazuhito Yokoi, Kensuke Harada, Yoshio Matsumoto) Chap. 57. Safety for Physical Human-Robot Interaction (Antonio Bicchi, Michael Peshkin, Edward Colgate) Chap. 58. Social Robots that Interact with People (Cynthia Breazeal, Atsuo Takanishi, Tetsunori Kobayashi) Chap. 59. Robot Programming by Demonstration (Aude Billard, Sylvain Calinon, Ruediger Dillmann, Stefan Schaal) Chap. 60. Biologically-Inspired Robots (Jean-Arcady Meyer, Agnès Guillot) Chap. 61. Evolutionary Robotics (Dario Floreano, Phil Husbands, Stefano Nolfi) Chap. 62. Neurorobotics: From Vision to Action (Michael Arbib, Giorgio Metta, Patrick van der Smagt) Chap. 63. Perceptual Robotics (Heinrich Bülthoff, Christian Wallraven, Martin Giese) Chap. 64. Roboethics: Social and Ethical Implications (Gianmarco Veruggio, Fiorella Operto) Elektrotechnik Energietechnik Basic Principles and Methods of Robotics Biologically-Inspired Robots Industrial Robotics Life-Like Robotics Manipulation and Interfaces of Robots Mobile and Distributed Robotics Roboethics Roboter Robotics Foundations Robot Structures Sensing and Perception of Robots Springer Handbook of Robotics ISBN-10 3-540-23957-X 354023957X ISBN-13 978-3-540-23957-4 9783540239574 Acknowledgements. - Subject Index. - About the Authors From the reviewsA comprehensive collection of the international accomplishments in the field and presents the very latest research in robotics. … Designed for research and practice, the handbook is edited by the internationally renowned robotics experts … . The coverage of all specialist fields infringing into robotics makes this handbook a reliable desk reference for scientists and engineers in the industry. It also provides basic and more advanced content for scholars from related disciplines such as biomechanics, neurosciences, virtual simulation, animation, surgery, and sensor networks, among others.  (Renate Bayaz, EurekAlert!, May, 2008) Together with Oussama Khatib, who is a Professor of Computer Science at Stanford University, Siciliano has edited and launched a ‘Handbook of Robotics’ that aims to make the increasingly complex field of robotics more accessible to engineers, doctors, computer scientists and designers. … The handbook was conceived to provide a valuable resource not only for robotics experts, but also for newcomers to this expanding field [such as] engineers, medical doctors, computer scientists, and designers.  (Liz Tay, iTnews, June, 2008) The ‘Springer Handbook of Robotics’ … basically differs from other handbooks of robotics focusing on industrial applications. It presents a widespread and well-structured coverage from the foundations of robotics, through the consolidated methodologies and technologies, up to the new emerging application areas of robotics. The handbook is an ideal resource for robotics experts but also for people new to this expanding field such as engineers, medical doctors, computer scientists, designers; edited by two internationally renowned experts.  (Amazon, Juni, 2008) Siciliano and Khatib have assembled a massive and comprehensive tome on robotics, circa 2008. Sections of the book can be read by a diverse audience of undergraduate and graduate students, researchers and even the general public. Spanning any field associated with the subject.  (W Boudville, Amazon, Juni, 2008) The handbook is a very large and truly encyclopedic work, covering all aspects of robotics, from fundamental principles to applications. The book’s 1, 600 pages are subdivided into seven parts … . Each of the seven parts is subdivided into multiple chapters, all written by experts in their fields throughout the world. … This amazing book does an incredible job of balancing theory and practice throughout. It should be an immensely valuable reference for students and practitioners of robotics for many years to come.  (George A. Bekey, IEEE Robotics and Automation Magazine, September, 2008) The book’s seven parts and 64 chapters concisely review wholesomely ‘traditional’ applications of robotics, as well as address emerging questions of the science and technology of robots. … The volume is rich in indexes and lists. The accompanying DVD- ROM assists readers in perusing the topics. This is a must-have work for anyone with even a remote interest and interaction with this field. … Summing UpEssential. Graduate students, researchers, faculty, professionals, and informed general readers.  (G. Trajkovski, Choice, Vol. 46 (6), February, 2009) SynopsisRobotics is undergoing a major transformation in scope and dimension. Starting from a predominantly industrial focus, robotics has been rapidly expanding into the challenges of unstructured environments. The Springer Handbookof Robotics incorporates these new developments and therefore basically differs from other handbooks of robotics focusing on industrial applications. It presents a widespread and well-structured conglomeration of new emerging application areas of robotics. The handbook is an ideal resource for robotics experts but also for people new to this expanding field such as engineers, medical doctors, computer scientists, designers; edited by two internationally renowned experts. Bruno Siciliano is Professor of Control and Robotics at University of Naples, President-Elect and Distinguished Lecturer of the IEEE Robotics and Automation Society, and he is on the board of the European Robotics Research Network. He is a Fellow of both IEEE and ASME. Oussama Khatib is Professor at Stanford University, President of IFRR, the International Foundation of Robotics Research, Distinguished Lecturer of the IEEE Robotics and Automation Society and a recipient of the JARA (Japan Robot Association) Award in Research and Development. He is a Fellow of the IEEE. Die Urgesteine der Robotik Bruno und Oussama haben sich mächtig ins Zeug gelegt, um die all die Korryphäen dieser Welt im Bereich Robotik zu einem gemeinsamen Standardwerk zusammen zu bringen. Hut ab - das ist ihnen gelungen. In dem Fach-Buch lässt sich viel über Robotertechnik lernen - und ist eine Abbildung des aktuellen Forschungs- und Wissenstands im Dunstkreis von Robotern. Das Buch ist ein wenig dick und schwer, so eignet es sich eher am Schreibtisch als im Freibad zu lesen - glücklicherweise gibt es zusätzlich die DVD, auf der das Buch in PDF drauf ist. So kann man hier Volltextsuche machen, und auf einem tragbaren Lesegerät (Laptop) das Ding doch ins Freibad mitnehmen;) Springer Handbook of Robotics Incl DVD [Englisch] [Gebundene Ausgabe] von Bruno Siciliano (Herausgeber), Oussama Khatib (Herausgeber)Beispielbild für diese ISBN

Springer Handbook of Robotics Incl DVD [Englisch] [Gebundene Ausgabe] Methods of Robotics Biologica…

4,47 Ødurchschnittliche Bewertung · 36 Bewertungen bei Goodreads

von Bruno Siciliano Verlag: Springer

Auflage: 2008 (20. Mai 2008) Auflage: 2008 (20. Mai 2008) Hardcover 1611 S. 19,3 x 7,6 x 24,2 cm Zustand: gebraucht - sehr gut, A new, authoritative and utterly comprehensive reference work on robotics that incorporates new developments, surpassing the narrow scope of other robotics handbooks tha…

Bestell-Nr.: BN22299
ISBN: 354023957X
Anbieter: BUCHSERVICE / ANTIQUARIAT Lars-Lutzer *** LITERA…, Wahlstedt, Deutschland

Verkäufer akzeptiert PayPal

479,90 EUR

zzgl. 6,99 EUR Verpackung & Versand